
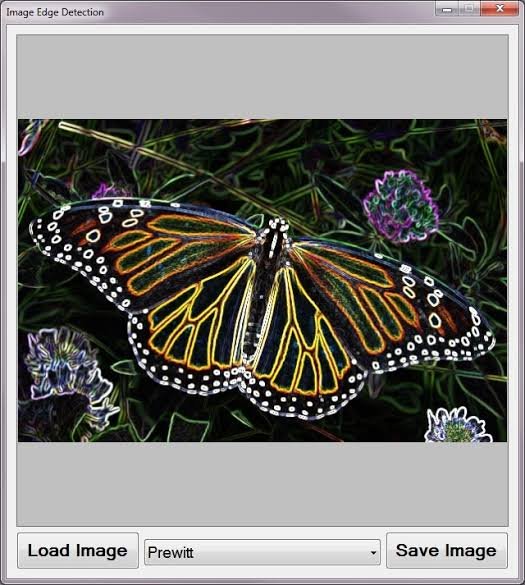
Every digital image is a grid of pixels, each carrying a specific brightness value. When that value changes sharply between neighbouring pixels, it signals a boundary, an object outline, or a surface transition. Edge detection filters are the tools that locate these changes automatically. They form one of the most foundational techniques in computer vision and image processing, powering applications from medical imaging to autonomous vehicles. Understanding how these filters work helps anyone pursuing a career in AI or machine learning build a stronger technical foundation.
What Is Edge Detection?
An edge in an image is defined as a region where pixel intensity changes significantly over a short distance. These transitions correspond to real-world boundaries such as the border between a light background and a dark object, or the outline of a face in a photograph.
Edge detection filters scan an image systematically, measuring how much the brightness changes between a pixel and its immediate neighbours. Where the change is large, the filter marks it as an edge. Where the values are nearly uniform, no edge is recorded.
The output is typically a greyscale or binary image in which bright lines represent detected edges and dark areas represent smooth regions.
Common Edge Detection Filters
Sobel Filter
The Sobel filter uses two separate 3×3 kernels, one for detecting horizontal changes and one for vertical changes. It calculates the gradient, meaning the rate of intensity change, in both directions and then combines them into a single edge magnitude value. Sobel is widely used because it reduces noise sensitivity while still producing clear edge maps.
Prewitt Filter
The Prewitt filter works on a principle similar to Sobel but uses slightly different kernel values. It is computationally simple and well-suited for images with moderate noise levels. It also applies separate horizontal and vertical kernels and then merges the results.
Laplacian Filter
Unlike Sobel and Prewitt, the Laplacian filter uses a single kernel that detects edges in all directions simultaneously. It looks for points where the second derivative of pixel intensity crosses zero, known as zero crossings. Because it responds to all directional changes, it can be more sensitive to noise, so it is often applied after a Gaussian blur is used to smooth the image first.
Canny Edge Detector
The Canny algorithm is considered the gold standard for edge detection. It involves multiple steps: applying a Gaussian filter to reduce noise, computing the gradient magnitude and direction, applying non-maximum suppression to thin edges, and using a double threshold to classify strong and weak edges. The result is a clean, precise edge map that performs well across a wide range of image types. Many professionals who enrol in an AI institute in Delhi encounter Canny edge detection early in their computer vision curriculum because of its practical reliability.
How Pixel Intensity Drives Edge Detection
At the core of every edge detection method is the concept of a spatial gradient. A gradient measures how quickly intensity values change across pixels. Mathematically, this is computed by convolving a kernel, a small matrix of numbers, with the image.
When the kernel slides over a uniform region, the output value is close to zero. When it passes over a sharp boundary, the output spikes. This spike is what the filter records as an edge.
The choice of kernel size and values directly affects the quality of results. Larger kernels capture broader intensity transitions but can miss fine details. Smaller kernels are more precise but more vulnerable to noise artefacts.
Practical Applications of Edge Detection
Edge detection filters are embedded in a wide range of real-world systems:
- Medical imaging: Detecting tumour boundaries in MRI and CT scans
- Autonomous vehicles: Identifying lane markings, pedestrians, and road signs
- Industrial inspection: Spotting defects in manufactured components
- Object recognition: Feeding clean edge data into deep learning models for classification tasks
For learners exploring these domains, enrolling in an AI institute in Delhi that includes hands-on computer vision modules provides direct exposure to implementing and tuning these filters using libraries such as OpenCV and scikit-image.
Conclusion
Edge detection filters are precise tools for identifying meaningful structural information within images. By measuring sharp changes in brightness and pixel intensity, filters like Sobel, Prewitt, Laplacian, and Canny transform raw image data into structured visual information that downstream AI models can use effectively. Mastering these techniques gives practitioners a reliable foundation for tackling more complex problems in image segmentation, object detection, and scene understanding.